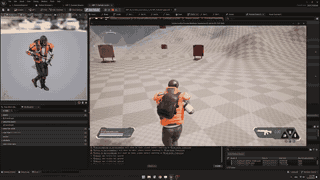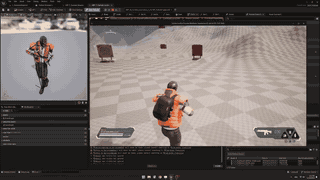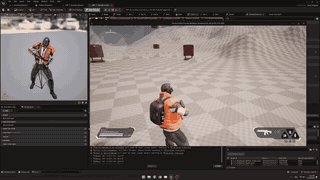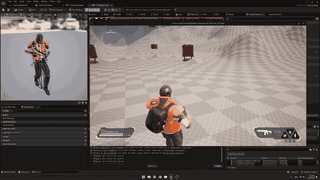
Geometry-based rigging (Khosrobot)
Mechanical rigging driven by calculus and geometry, made for an AR project.
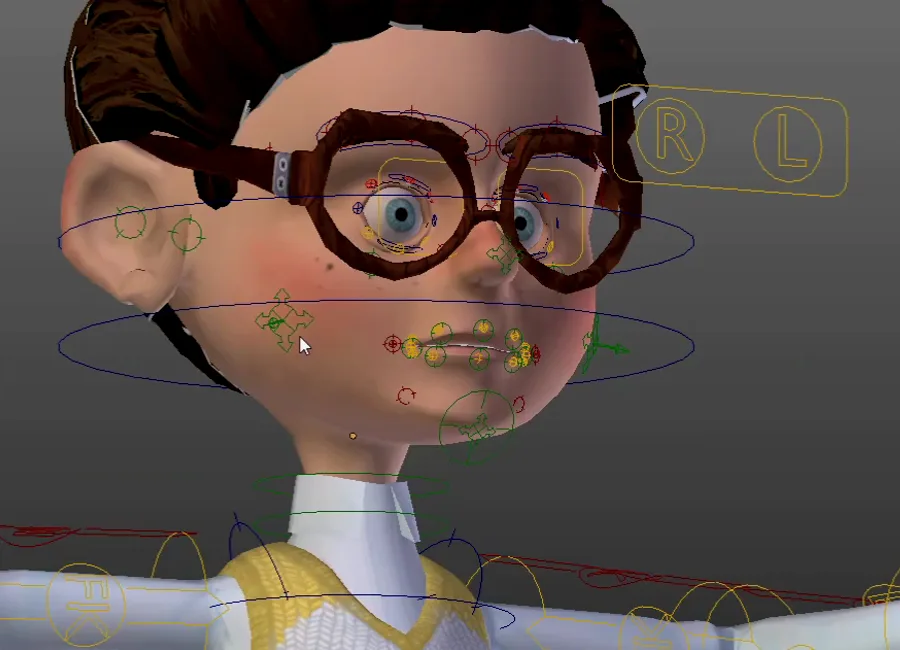
A precise and fast kind of rigging, fairly hard to implement, made for an AR project. It suits mechanical rigs best, since they are built from pseudo-primitive shapes, but it also works for organic characters with some approximation.
01 Problem
A mechanical character for an AR project needed a rig that was precise, fast and easy to export to engines and mobile platforms.
02 Idea
The rig applies calculus and geometric algorithms. The main wheel of the character rolls precisely on its bottom surface and never enters it; the surface has its own controller and can be transformed separately. The Newton-Raphson method solves the corresponding equations. The teeth push each other aside on collision using simple calculations. The rotation of the elbow hinges and the telescoping arms come from a set of 3D-geometry equations, and some linear algebra drives the crown, eyes and hands. Because such rigs are low-level and fast, they export easily to game engines and run well on mobile platforms.
03 Result
A low-level, fast rig that exports easily to game engines and runs on mobile platforms.